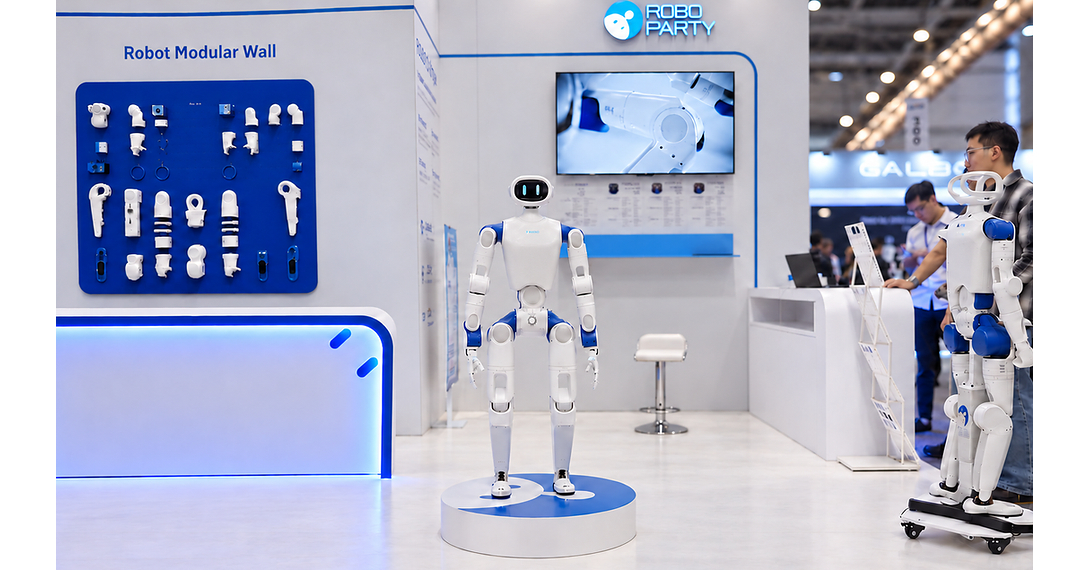


Pittsburgh, October 3, 2026 / PRNewswire / -- RoboParty was publicly released on IROS on September 28, 2026, marking the global debut of this robot. RP1 is built upon the foundation of RPO ( ROBOTO ORIGIN ). RPO is a fully open-source humanoid robot project launched by RoboParty in January 2026, with over 2,500 stars (likes). RoboParty positions RP1 as the world's first high-performance, full-stack open-source bipedal humanoid robot, aimed at researchers, educators, robot developers, and AI teams.
At the company's IROS booth, an interactive demonstration named “Kick Me” allowed visitors to directly push and kick the robot. RP1 quickly adjusted its posture and regained balance under these external disturbances, which was used to test its dynamic stability, physical performance, and system-level robustness. The aforementioned capabilities are supported by PartyOS. PartyOS is an open research and development foundation developed by RoboParty for humanoid robots, integrating UFO – a training framework that discovers humanoid motion skills through unsupervised reinforcement learning, covering skill switching, disturbance recovery, and fall recovery, without the need to rely on predefined action trajectories.
RoboParty is integrating the robot body, actuator modules, underlying control systems, and the AI algorithm into a single system for continuous joint verification. The peak joint torque of RP1 can reach up to 160 N•m, and it utilizes the company's self-developed Romomo actuator modules along with a real-time motion control system.
RoboParty indicates that "full-stack open-source" is not just about making mechanical files available. The company plans to gradually make its motion control systems, simulation environments, SDK, training tools, and the PartyOS development foundation available as well, allowing developers to be involved from hardware and low-level control all the way to model training and deployment.
RoboParty founder Huang Yi stated: "Humanoid robots should not be closed systems, accessible only to a few teams while others can only watch from the sidelines. We hope that RP1 will become an open platform where developers can access, modify, train, and continuously improve them."
RP1 is built upon the verified open-source robot ontology and workflow of RPO, the Romomo executor modules, as well as the agile RP Hand. PartyOS continues to evolve in areas such as bipedal walking, perceptual interaction, full-body manipulation, and autonomous intelligent humanoid robots.
Core team members have studied at prestigious institutions such as Tsinghua University's Yao Class, Peking University's Zhi Class, Harbin Institute of Technology, Stanford University, Carnegie Mellon University, and Zhejiang University. RoboParty stated that the company has established a global community of over 5,000 developers and will announce more details of its open-source roadmap in October 2026. By then, additional software and hardware will be released, and mass production plans will be advanced later in the fourth quarter of this year.
Media contact: [ email protected ]
GitHub : https :// github.com / Roboparty /roboto_origin
Website: https :// roboparty.com /